Will Davis MIET BEng MSc

Automation / Controls / Hardware

I design control and safety systems for machines, mostly on Beckhoff TwinCAT 3 and EtherCAT. I'm currently a hardware engineer at Rivelin Robotics, where I lead the TwinSAFE projects. Before that I commissioned safety-critical servo winches and hoists to IEC 61508 at TAIT.

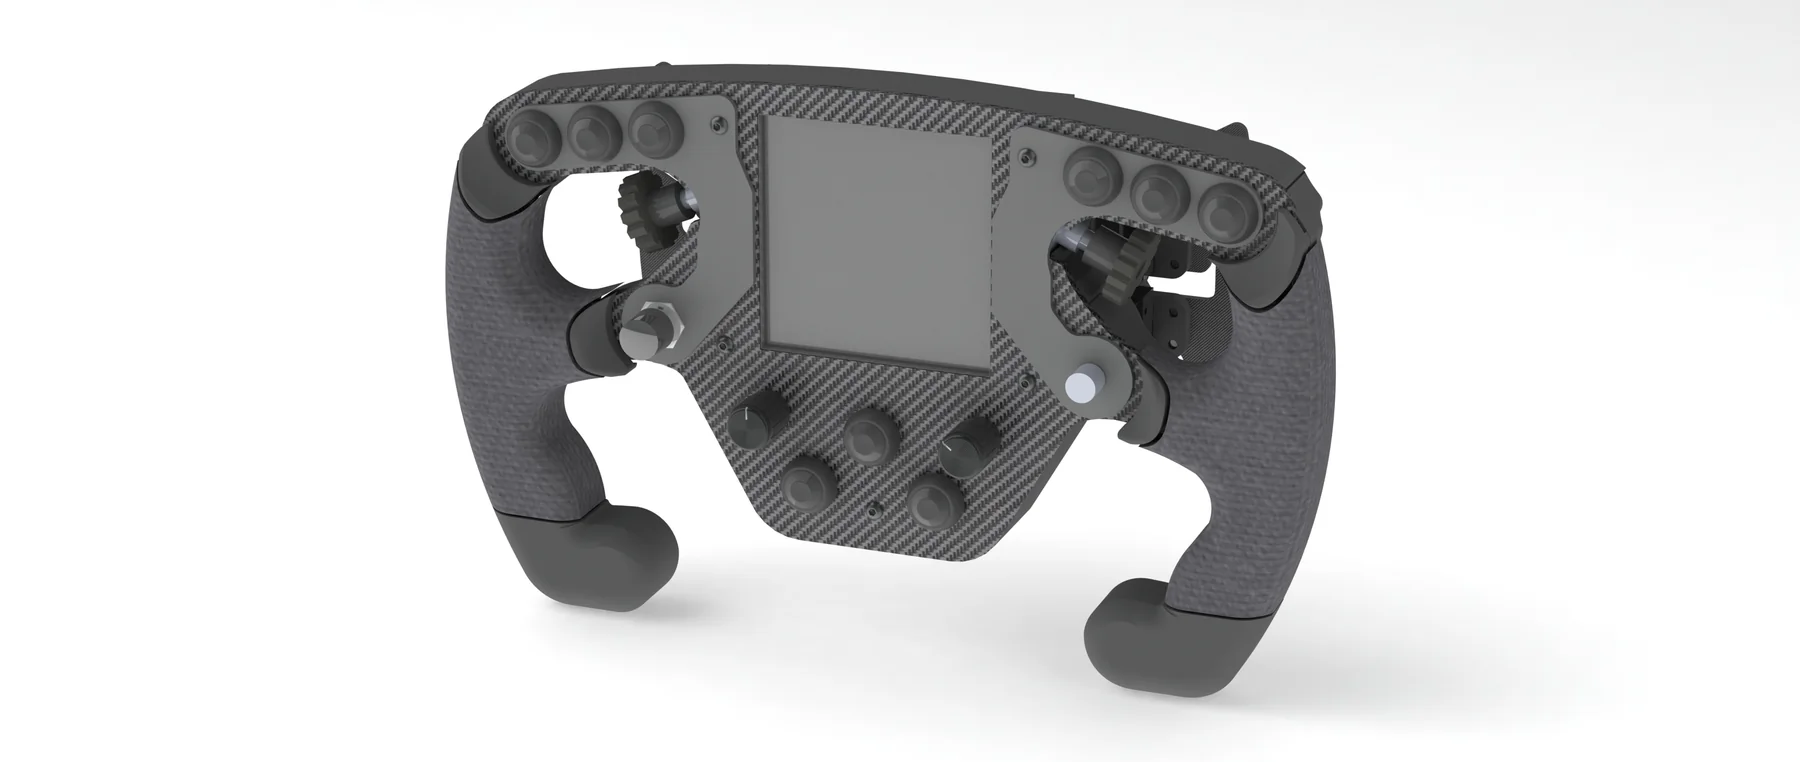
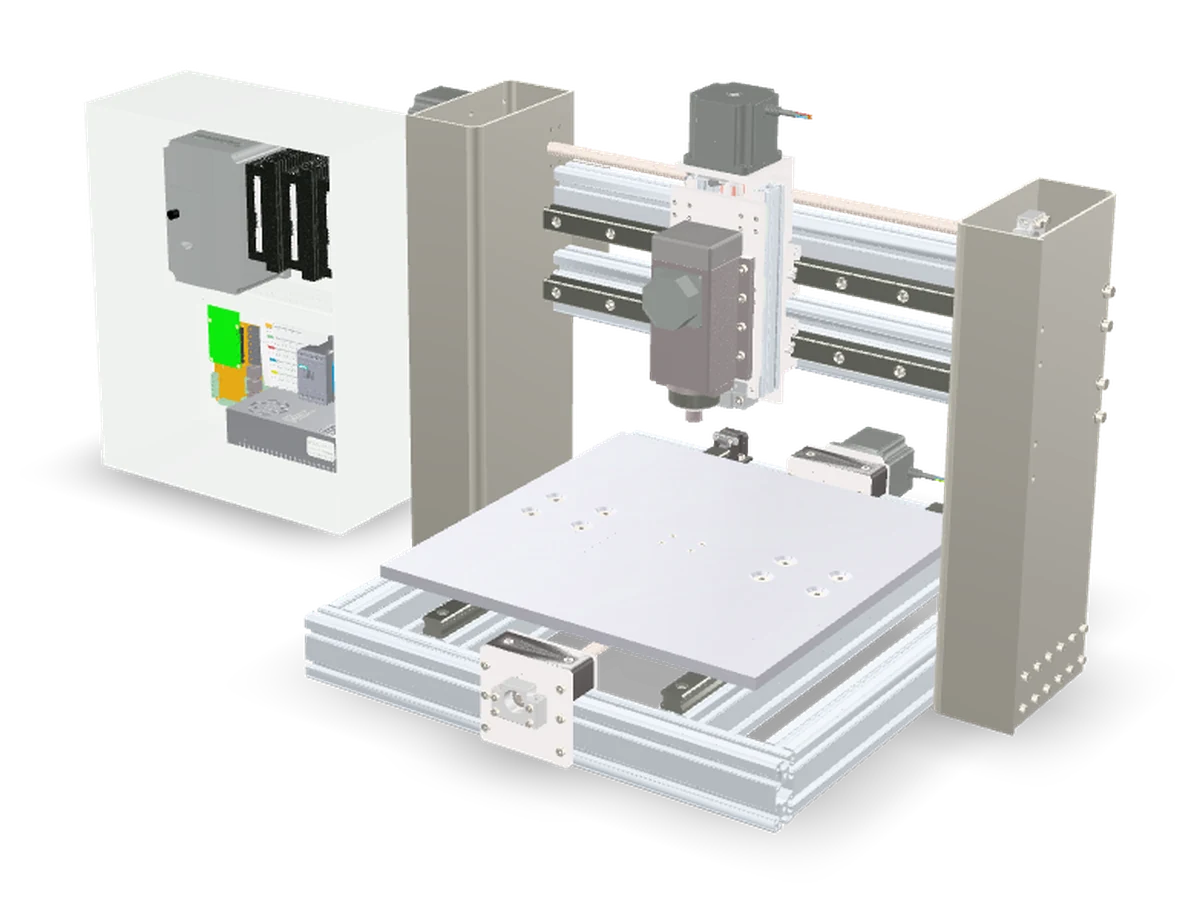
Outside work I build my own machines end to end: a Beckhoff-controlled CNC router, a custom EtherCAT slave on STM32, a CAN bus automotive gauge and a force-feedback sim racing rig.

Current
Hardware Engineer, Rivelin Robotics
Platforms
Beckhoff TwinCAT 3, TwinSAFE, EtherCAT, Siemens TIA Portal / Simotion
Standards
IEC 61508, EN 17206
Education
MSc by Research, Digital Twins
BEng Mechatronics (First Class)
Award
WorldSkills UK Gold, Mechatronics
Based
UK

Experience

Rivelin Robotics

Hardware Engineer · Sheffield
Jun 2025 – present
  • Lead engineer on TwinSAFE functional safety projects for Beckhoff-controlled robotic systems: safety logic, safety I/O architecture, and validation of emergency stops and guard interlocking.
  • Develop and integrate TwinCAT 3 control systems that bring robots, sensors and third-party devices together over EtherCAT.
  • Design control panels, electrical schematics and CAD for robotic tooling, enclosures and automation cells.
  • Run prototyping, validation and in-house testing so systems go out reliable, safe and production ready.
TAIT

Controls Engineer · Wakefield
Jan 2023 – Jun 2025
  • Wrote, tested and debugged machine code for performer-flying servo winches and hoists across Beckhoff TwinCAT, Siemens Simotion / S120, Brilliant, Kinesys and Nidec platforms.
  • Commissioned safety-critical motion systems through FAT and SAT to EN 17206 and IEC 61508.
  • Integrated Pilz and DOLD safety controllers with SEW and Control Techniques motors, and tuned each system before it shipped to site.
  • Managed a controls apprentice and a controls technician; created and redlined wiring diagrams.

Projects

Machines and hardware I've designed and built myself.

Custom EtherCAT slave on STM32

2026

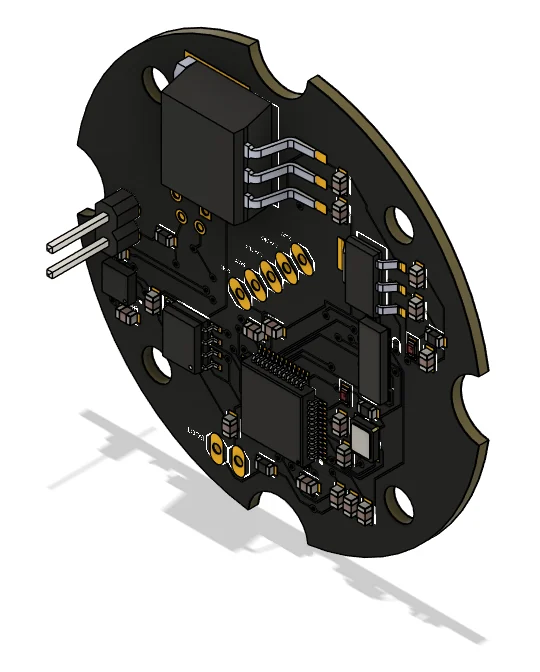
Custom EtherCAT slave firmware for my own STM32 board, with a hand-written ESI (EtherCAT Slave Information) file so TwinCAT scans, configures and maps its process data like any commercial terminal. Building a device from the slave side gave me a much better understanding of EtherCAT when integrating third-party hardware.

STM32 · C · EtherCAT · ESI (XML) · TwinCAT 3

Digital twin of an Industry 4.0 production line

MSc research, Middlesex University

A software-agnostic Unity digital twin of the Festo cyber-physical factory at Middlesex University, reading data from multiple Siemens PLCs at different rates over TCP/IP to track part positions in real time. I used it for trend-based fault detection (air flow against regulated pressure for leaks, per-station power draw for bearing and motor strain), validation of production efficiency against historical data, and obstruction detection. The work fed into the publications below.

Siemens TIA Portal · CODESYS · Unity · C# · Python · Node-RED · TCP/IP

Publications

From my research on digital twins and traceability at Middlesex University.

  1. 2022
    Digital Twins: A Survey on Enabling Technologies, Challenges, Trends and Future Prospects
    S. Mihai, M. Yaqoob, D. V. Hung, W. Davis, et al.
    IEEE Communications Surveys & Tutorials, vol. 24, no. 4, pp. 2255–2291
  2. 2022
    An Innovative Blockchain-Based Traceability Framework for Industry 4.0 Cyber-Physical Factory
    W. Davis, M. Yaqoob, L. Bennett, S. Mihai, D. V. Hung, R. Trestian, M. Karamanoglu, B. Barn, H. X. Nguyen
    11th International Conference on Industrial Technology and Management (ICITM), Oxford
  3. 2020
    A Digital Twin Framework for Predictive Maintenance in Industry 4.0
    S. Mihai, W. Davis, D. V. Hung, R. Trestian, M. Karamanoglu, B. Barn, R. Prasad, H. Venkataraman, H. X. Nguyen
    International Conference on High Performance Computing & Simulation (HPCS), Barcelona (virtual)
  4. 2020
    A Digital Twin Framework for Industry 4.0 Enabling Next-Gen Manufacturing
    M. Raza, P. M. Kumar, D. V. Hung, W. Davis, H. Nguyen, R. Trestian
    9th International Conference on Industrial Technology and Management (ICITM), Oxford, pp. 73–77

Skills

PLC & controls
Beckhoff TwinCAT 3 (PLC, Motion, TwinSAFE, I/O), IEC 61131-3 Structured Text, CODESYS, Siemens TIA Portal / STEP 7, Siemens Simotion
Motion & drives
EtherCAT servo and stepper axes, Siemens S120, Nidec, Kinesys, SEW, Control Techniques, ODrive; servo winch and hoist commissioning
Functional safety
Beckhoff TwinSAFE, Pilz, DOLD; IEC 61508, EN 17206; FAT and SAT
Fieldbus & integration
EtherCAT (including slave firmware and ESI files), CAN bus, TCP/IP, SPI, QSPI, serial
Software
C, C++, C#, Python, Git, Node-RED, Unity, LabVIEW, Linux
Robotics & simulation
ABB RobotStudio, ROS, Festo Robotino, Siemens Plant Simulation, digital twins of PLC-controlled lines
Hardware & CAD
Control panel design and wiring, electrical schematics, SolidWorks, Siemens NX, Autodesk Fusion (Design & Electronics), KiCad, STM32

Education & awards

MSc by Research

Middlesex University, London
2020 – 2024

Digital twin technology with the application of Industry 4.0 manufacturing.

BEng Mechatronics, Robotics and Automation, First Class Honours

Middlesex University, London
2016 – 2019

Major project: applying blockchain product tracing to an Industry 4.0 production line.

WorldSkills UK Gold Medal, Higher Mechatronics

Recruited into Squad UK
2018

Level 3 Engineering Diploma; A Levels in Maths, Further Maths and Physics

Sheffield University Technical College
2014 – 2016